- 0.4 kg module mass A third of the weight of the 1.2 kg mid-range joints, which cuts the inertia the shoulder and elbow have to accelerate.
- Ø57 × 57 mm envelope The smallest housing in the range, sized to fit inside slim forearms, wrist stacks and camera heads.
- 156 rpm no-load output The fastest output speed in the Xynova range, suited to quick wrist rotation and natural head movement.
- 25 Nm peak torque Sized for light distal loads such as a dexterous hand, a gripper or a sensor package rather than heavy tooling.
- 16-bit encoder Supports repeatability of 0.1° or better, the same figure as the larger arm modules.
- 48 V input shared with the range One supply voltage runs the whole limb, from the hip joint down to the wrist.

Description
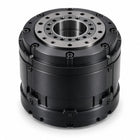
Mass at the end of a limb is paid for by every joint behind it. The PRH19-57-25-HS is Xynova's answer for those distal axes: 0.4 kg in a Ø57 × 57 mm cube, with 25 Nm of peak torque and the fastest output in the range at 156 rpm.
It is a third the mass of the mid-range arm modules and a little over half their diameter, which is what makes it fit inside a slim forearm, a wrist stack or a sensor head. The 19:1 reduction keeps the output quick, a 16-bit encoder supports repeatability of 0.1° or better, and the 48 V input matches the rest of the range so a limb needs only one supply voltage.
Torque density is the lowest in the family at 63 Nm/kg, and that is the honest trade: this module is bought for size, mass and speed, not for torque per kilogram. Joints that carry a heavy tool or take impact loads belong on a mid-range module instead.
The torque figure is a peak rating. Rated continuous torque, rated current, the communication interface and the meaning of the PRH prefix and HS suffix are confirmed with the quotation.
Key Capabilities
- 0.4 kg module mass: A third of the weight of the 1.2 kg mid-range joints, which cuts the inertia the shoulder and elbow have to accelerate.
- Ø57 × 57 mm envelope: The smallest housing in the range, sized to fit inside slim forearms, wrist stacks and camera heads.
- 156 rpm no-load output: The fastest output speed in the Xynova range, suited to quick wrist rotation and natural head movement.
- 25 Nm peak torque: Sized for light distal loads such as a dexterous hand, a gripper or a sensor package rather than heavy tooling.
- 16-bit encoder: Supports repeatability of 0.1° or better, the same figure as the larger arm modules.
- 48 V input shared with the range: One supply voltage runs the whole limb, from the hip joint down to the wrist.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Type | Integrated planetary joint module |
|---|---|
| Model | PRH19-57-25-HS |
| Peak torque | 25 Nm |
| No-load speed | 156 rpm |
| Gear ratio | 19:1 |
| Torque density | 63 Nm/kg |
| Weight | 0.4 kg |
| Size | Ø57 × 57 mm |
| Encoder resolution | 16-bit |
| Repeatability | ≤0.1° |
| Input voltage | 48 V DC |
| Rated continuous torque | Confirm at quote |
| Rated current | Confirm at quote |
| Communication interface | Confirm at quote |
| PRH prefix and HS suffix definition | Confirm at quote |
| Price | Quotation only |
Industries
Frequently Asked Questions
Distal axes that move often and carry light loads: wrist pitch, roll and yaw, forearm rotation, neck and head joints, and end-effector orientation.
The module measures Ø57 × 57 mm and weighs 0.4 kg, a third of the mass of the 1.2 kg mid-range joints.
156 rpm at no load through a 19:1 reduction, the fastest output in the Xynova rotary range.
At 63 Nm/kg it is bought for envelope, mass and speed rather than torque per kilogram. A wrist taking heavy tooling or impact loads should use a mid-range module.
It is offered by quotation — quantity, configuration and delivery are confirmed per project.
A fully articulated wrist usually takes two or three axes. Tell us the joint layout and we will quote the set.
Recently Viewed
You haven't viewed any products yet.